 robotindex
Linorobot2
A ROS2 software and micro-ROS firmware framework for building DIY mobile robots — not a fixed robot with a bill of materials the way most entries here are. Builders bring their own chassis and a supported menu of microcontrollers, motor drivers, LiDARs, and cameras; the pictured unit is a lab-built Mecanum-wheel robot running Linorobot2 on hardware its own builder sourced and assembled.
linorobot.org →
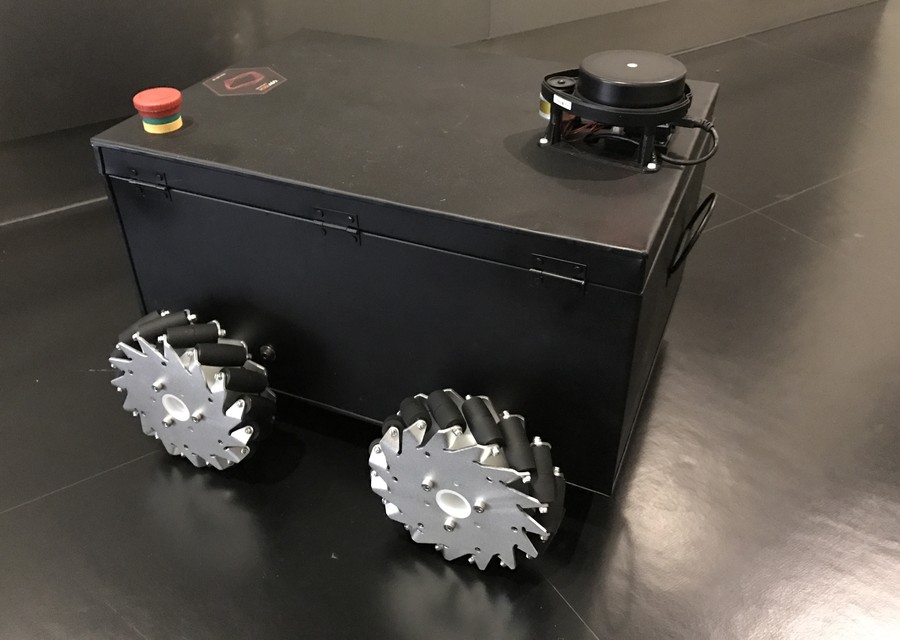
Image: user-submitted
Specs
Weight
Not publishedbring-your-own-chassis framework — no fixed robot to weigh
Dimensions
Not publishedbring-your-own-chassis framework — depends entirely on builder's design
Compute
Raspberry Pi-class SBCcommunity builds also use other Linux SBCs (e.g. Radxa ROCK 5C)
Software
ROS2 Humble/Jazzy, Nav2 + SLAMGazebo simulation designed to mirror the physical robot
Type
ROS2 software + firmwarenot a fixed robot design — bring your own chassis
Drive Support
Diff, skid-steer, Mecanumthis build uses Mecanum wheels; framework covers multiple layouts
MCU
ESP32 family or Pi Picomicro-ROS firmware layer; Teensy support now deprecated
LiDAR
RPLIDAR, LD06/LD19, YDLIDAR2D SLAM; this unit's spinning sensor matches the supported class
Cameras / IMU
RealSense, ZED, OAK-D + IMUsbring-your-own from a supported component menu
E-Stop / QR Tag
Not part of the specalmost certainly this builder's own lab safety/inventory additions
Reference Price
There is no official reference cost, because Linorobot2 is a framework rather than a product with a bill of materials; a widely-cited community estimate puts a minimal electronics-only configuration at roughly $131, excluding the chassis, motors, wheels, compute board, battery, and any LiDAR or depth camera. A complete build like the one pictured, with a metal enclosure, Mecanum wheels, spinning LiDAR, and a compute SBC, would run well beyond that figure — likely several hundred to over a thousand dollars depending entirely on the components a builder chooses.
Insights
The Linorobot2 project itself is genuinely open source (Apache-2.0, ~1,000 GitHub stars, actively maintained). Moved from Under Review to a live listing: community builds continue to surface as recently as May 2026, including one running current ROS 2 Jazzy on a Radxa ROCK 5C, confirming the project is still active rather than stalled — the earlier Under Review status reflected a categorization question (framework vs. fixed product), not a doubt about whether it's still alive.
Firmware & Community
linorobot/linorobot2
Open-source ROS2 framework for DIY autonomous mobile robots — this is the framework's own repo.
Specs compiled from the Linorobot2 GitHub repositories, project site, and third-party community/technical write-ups as of this build. Because this is a bring-your-own-hardware framework, exact specs and cost depend entirely on the builder's own component choices — the figures here describe the supported range, not one fixed configuration. Continued activity confirmed via a May 2026 "Show and tell" community build (GitHub Discussion #220) demonstrating ROS 2 Jazzy support on a Radxa ROCK 5C — a user showcase rather than an official maintainer announcement, but real evidence the project is still in active use.