 robotindex
LeKiwi
A single-arm mobile manipulation rig from a University of Illinois student robotics group, built around Hugging Face's SO-ARM101 arm on a 3-omni-wheel holonomic "kiwi drive" base. Deeply integrated as a native robot type in the official
huggingface.co/docs/lerobot/lekiwi →
lerobot Python package — a teleoperation/data-collection platform for training imitation-learning policies, not a navigation robot, and the design AlohaMini's own bimanual mobile base borrows from.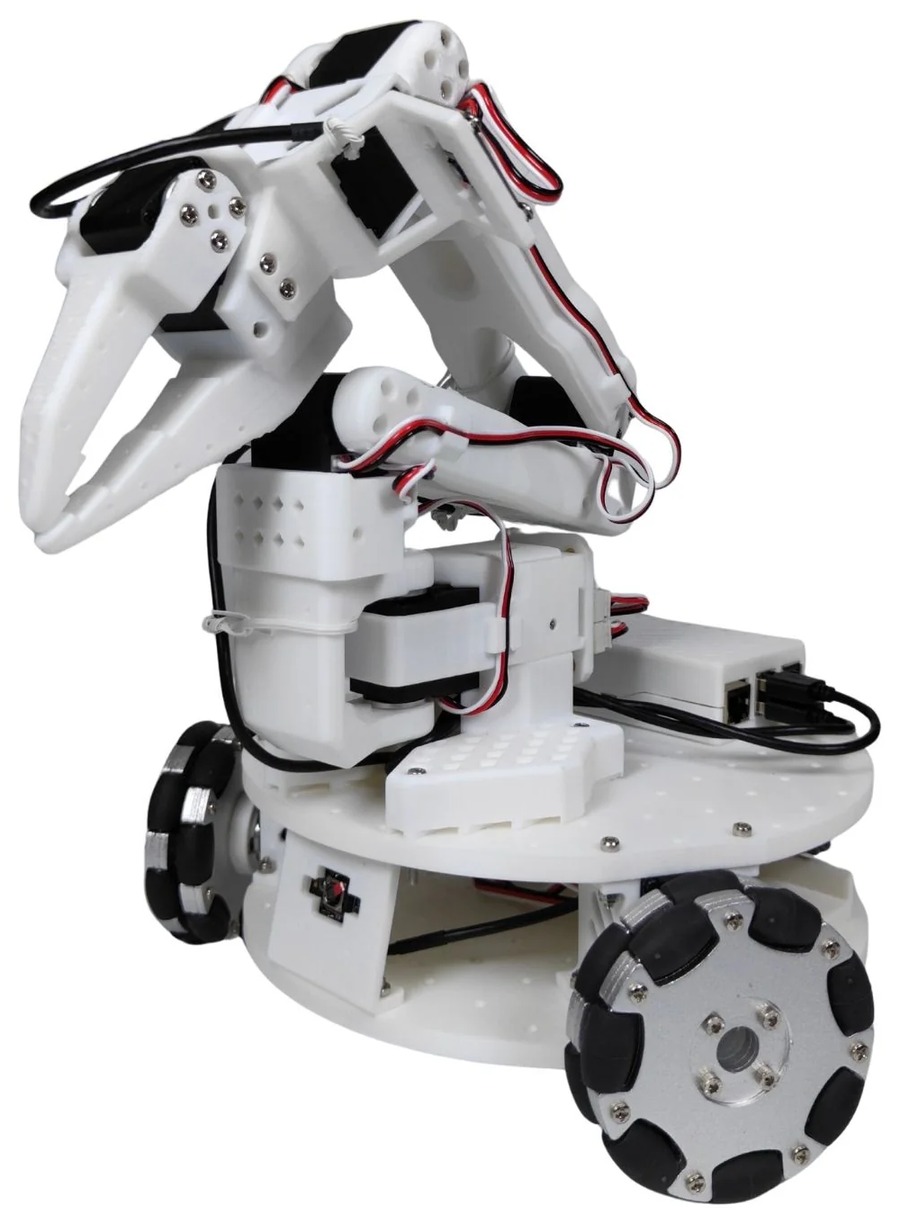
Image: user-submitted
Specs
Battery
12V Li-ion pack or USB-PD bankruntime undocumented; one vendor kit ships a 5,600mAh pack
Weight
Not publishedno official figure found in this research
Dimensions
Not publishedno official figure found in this research
Compute
Raspberry Pi 5swappable for any 5V PC/laptop; ZeroMQ networking, no ROS
Camera
Not standard across all kitssome vendor kits include one, others sell it separately — none visible on this unit
Software
Native
lerobot robot typeApache-2.0; ZeroMQ host/client architectureLocomotion
3-omni-wheel "kiwi drive"full holonomic motion; Feetech STS3215 bus servo per wheel
Arm
SO-ARM101, 6-DOFsame design shared across the LeRobot hardware family
Gripper
Stock 2-finger parallelPincOpen (Pollen Robotics) is a documented but non-default upgrade
Control
Leader-arm teleop + keyboard drivea second SO-100/101 arm puppeteers this one; WASD drives the base
Reference Price
No single official bill-of-materials total is published; reseller WowRobo (via OpenELAB) sells the omni-drive base alone for €302.85 without a Raspberry Pi, or €474.25 with a Pi 5 (4GB) included, with the SO-ARM101 arm shipping separately for typically $100–$250 depending on servo grade. Extrapolating a full self-build (base, arm, Pi, camera, battery) likely lands somewhere in the $400–$700+ range, though that's an estimate rather than a sourced figure.
Insights
LeKiwi's hardware and software are genuinely open under Apache-2.0, with an active if niche community (~1,400 GitHub stars).
Firmware & Community
SIGRobotics-UIUC/LeKiwi
Low-cost open-source holonomic mobile manipulator base.
Specs compiled from the LeKiwi GitHub repository, Hugging Face's official documentation, and vendor listings as of this build. Pricing, dimensions, weight, payload, and camera inclusion vary by vendor kit and were not fully standardizable — confirm the specific SKU before purchase.