 robotindex
Hugging Face LeRobot Humanoid
Open-source, 3D-printable bipedal research platform from Hugging Face. Currently released as a legs-only lower body for locomotion research — no torso, arms, or head yet. Anyone can print and assemble one.
Project page — huggingface.co/blog →
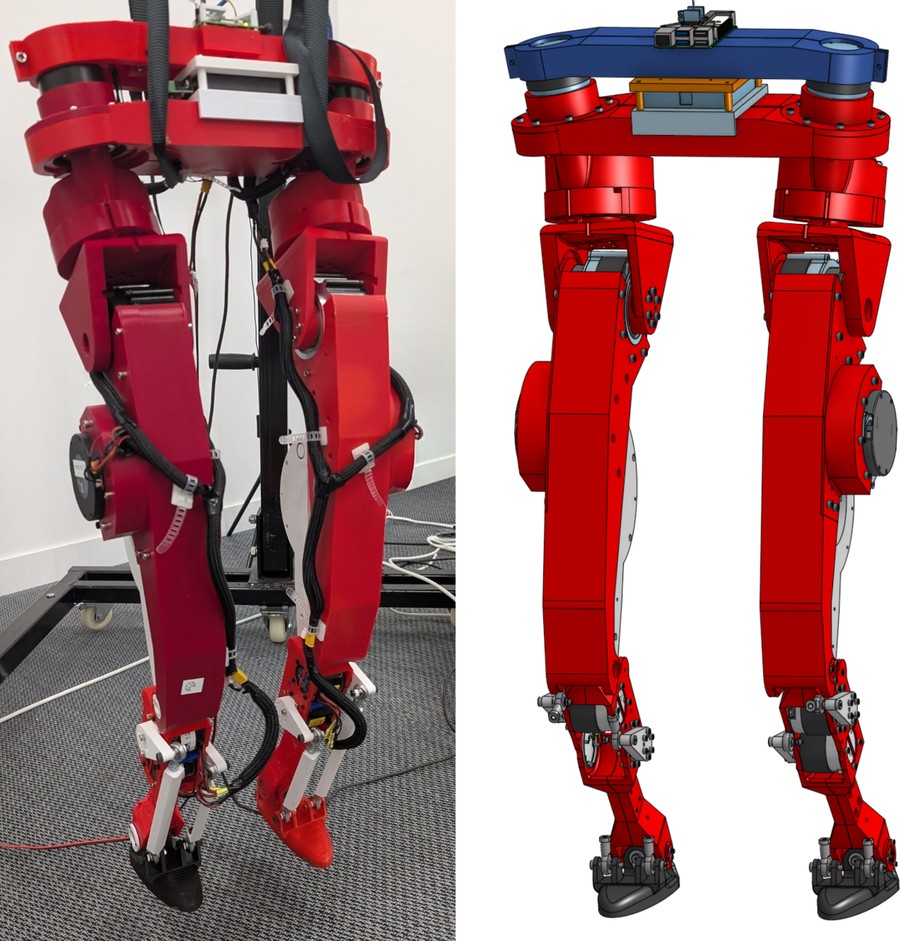
Image: Hugging Face / LeRobot project (official)
Specs
Weight
Not publishedno official figure found in this research
Height
Not publishedno official figure found in this research
Compute
Raspberry Pi 5+ BNO055/BNO085 IMU, SAVVYCANFD CAN-FD adapter
Software
LeRobot + MJLabsim-to-real training stack
Degrees of Freedom
12 actuated2 hip-x, 2 hip-z, 4 thigh, 4 shin — 6 per leg
Actuators
RobStrideO0 ×2 (torso), O2 ×2 (hip-z), O3 ×4 (thigh), O5 ×4 (shin)
Status
Experimentalrequires careful bring-up per HF's own docs
Configuration
Legs onlyupper body on roadmap, not yet released
Materials
3D-printed~75 STL parts, ~3.5kg of PLA+ filament
Capabilities
Standing / balancingearly sim-to-real policy — dynamic walking not yet independently confirmed
Reference Price
Roughly $2,500–$2,636 in parts, depending on sourcing, shipping, and taxes — this is a bill-of-materials for a self-build, not an assembled unit anyone sells. Height, weight, and payload haven't been published by Hugging Face as of this writing; independent coverage (Interesting Engineering, Hackster, Humanoids Daily) notes the same gap rather than filling it in.
Sensors & Hardware
Designed by Virgile Batto at Hugging Face LeRobot, this is a genuine first-party HF hardware project. It's built from ~75 3D-printed parts, RobStride brushless actuators, a Raspberry Pi 5 for compute, a BNO055/BNO085 IMU, and a SAVVYCANFD CAN-FD adapter. The hardware repo is Apache-2.0 licensed. Only the bipedal lower body has shipped; arm/torso manipulation is still on the roadmap.
Insights
Despite "humanoid" and "robot learning" marketing language, what's actually been demonstrated is an early sim-to-real standing/balancing policy, not confirmed dynamic bipedal walking across a room. Hugging Face's own team describes it as "an experimental research platform" where running policies on physical hardware "still requires careful calibration, low-gain testing, and a reliable power cutoff."
Firmware & Community
huggingface/lerobot-humanoid-hardware
BOM, STL files, and wiring/assembly docs (Apache-2.0). Sits alongside four sibling repos — lerobot-humanoid-design, -model, -runtime, and -identification — plus the base lerobot software framework.
Hugging Face LeRobot Humanoid
Open-source humanoid platform under the LeRobot project.
Specs compiled from Hugging Face's official project blog post, the huggingface/lerobot-humanoid GitHub org (hardware, design, model, runtime, and identification repos and their LICENSE files), and independent coverage from Interesting Engineering, Hackster.io, and Humanoids Daily. Height, weight, and payload remain unpublished by Hugging Face and are flagged as such rather than estimated. robotindex does not sell this product — it is a build-it-yourself open-source platform with no assembled unit available for purchase.