 robotindex
AlohaMini
A bimanual teleoperation and imitation-learning research rig, not a navigation robot — the mobile base and lift exist to position two arms for pick-and-place manipulation, controlled by physically puppeteering a matching leader arm, the same leader/follower concept Stanford's ALOHA popularized. Built by independent makers on Hugging Face's LeRobot ecosystem (SO-ARM100 arms, a LeKiwi-derived base), not by Stanford/Berkeley's original ALOHA team or Trossen Robotics, despite the shared name and borrowed design.
alohamini.com →
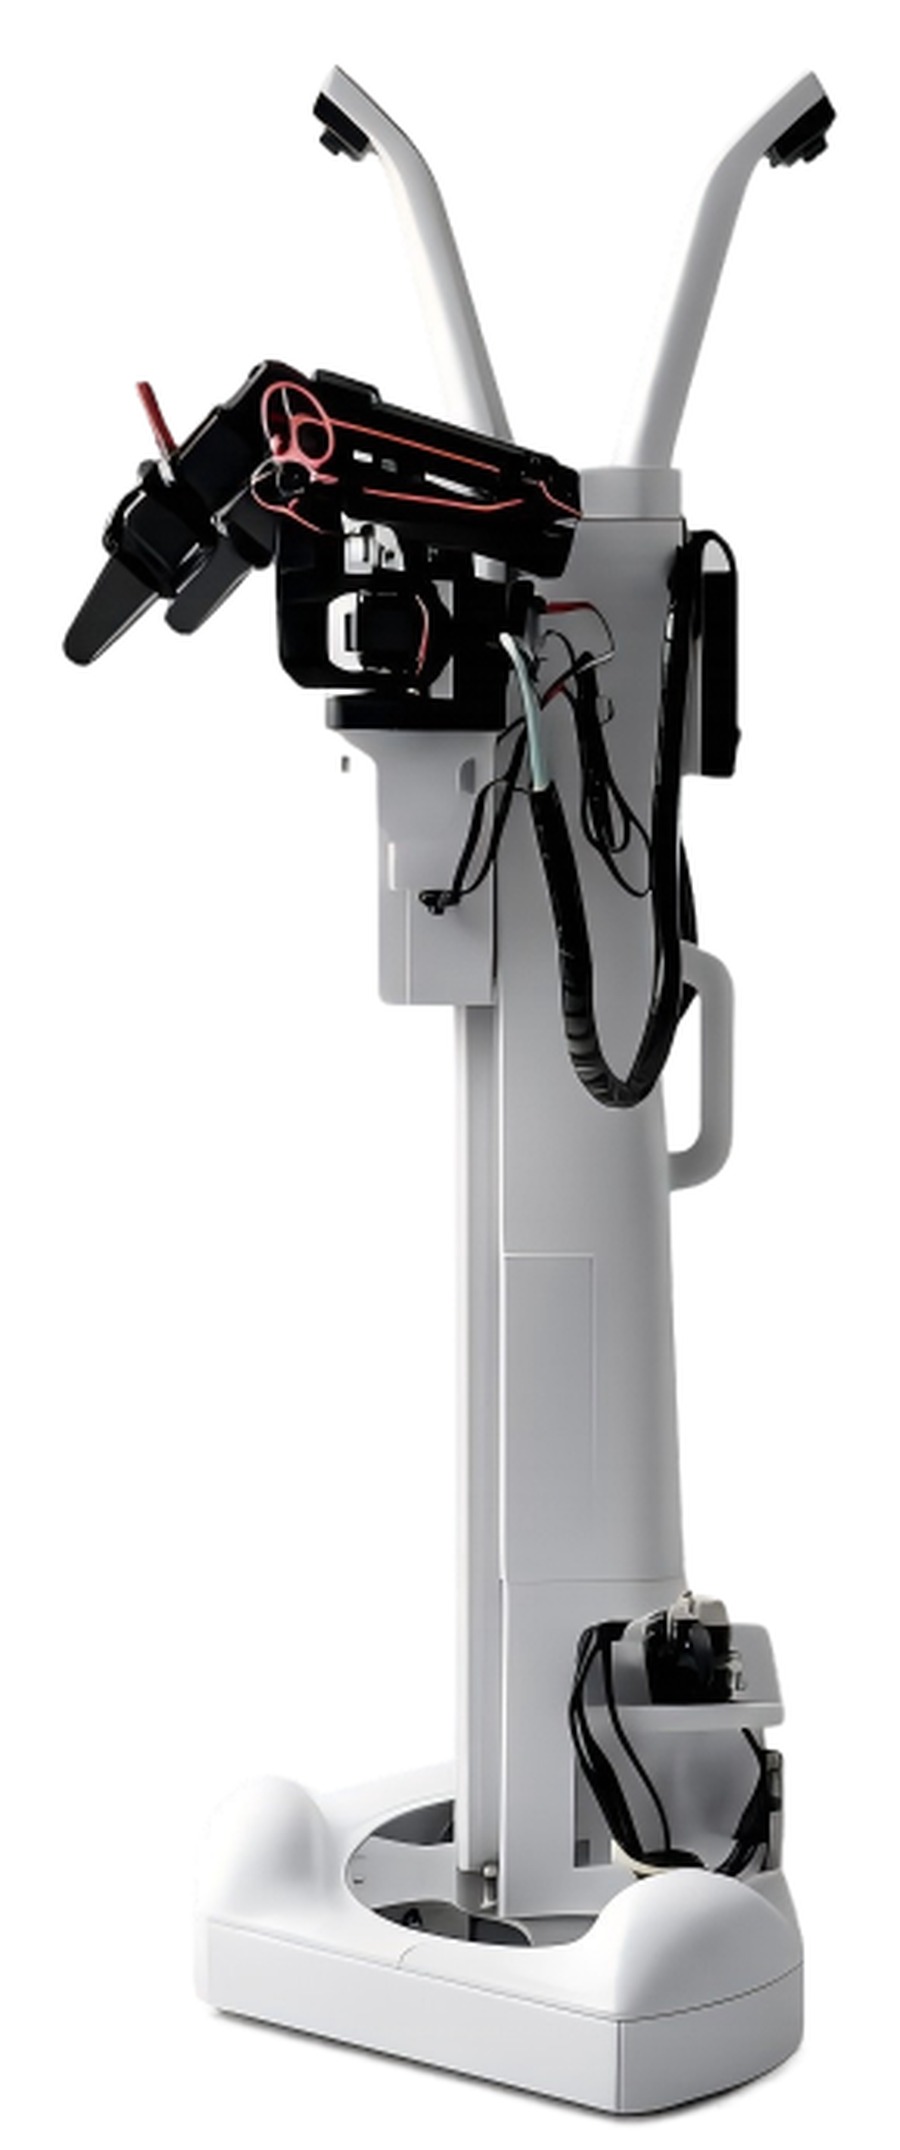
Image: user-submitted
Specs
Battery
2× 12V 11,200mAh Li-ionAlohaMini2 spec
Weight
~16 kgPro/Edu tier, per AlohaMini's official site; DIY kit is ~13.5kg
Dimensions
Not publishedno official L×W×H figure found in this research
Compute
Raspberry Pi 5swappable for Jetson Orin Nano or any USB3 SBC
Software
LeRobot forkACT, Diffusion Policy, Pi-0.5, SmolVLA — data collection, not a pre-trained robot
Arms
Bimanual, leader + followerAM-ARM200, 6+1 DOF each; Feetech STS3215/STS3095 bus servos
Mobile Base
3× omni-wheel, 3D-printedup to 70kg load rating (current AlohaMini2 generation)
Lift
Motorized vertical columnup to 30kg capacity (AlohaMini2)
Cameras
5× 720p USBfront, back, chest, dual wrist
Control
Physical leader-arm teleoperationa human puppeteers a matching arm — not joystick-driven
Reference Price
Pricing is scattered across sources: a DIY self-build from the project's own published bill of materials runs roughly $950–$1,100 in parts, and the project's own site lists assembled "Pro" tiers from $1,499 up to $2,699 for the 6-DOF version. A pre-built unit sold through third-party reseller PartaBot at $1,099 is currently out of stock/preorder-only, so that cheaper path isn't presently available.
Insights
AlohaMini is an independent open-source project — not built by Stanford/Berkeley's ALOHA research team or Trossen Robotics — assembled from Hugging Face LeRobot community hardware (TheRobotStudio's SO-ARM100 arm design and a LeKiwi-derived base), with real CAD, bill of materials, and code published under Apache-2.0. It borrows its bimanual leader/follower teleoperation concept from Stanford's original ALOHA, listed separately in Builds & Mods, while using its own, unrelated arm and base hardware. A separate claim of TechCrunch coverage and Hugging Face leadership endorsement, seen on one reseller's page, could not be verified anywhere else and isn't repeated here.
Firmware & Community
liyiteng/AlohaMini
Open-source 3D-printable dual-arm mobile robot, LeRobot-native.
ALOHA (tonyzhaozh/aloha)
Stanford's original bimanual leader/follower teleoperation design — the concept AlohaMini's own hardware builds on. MIT-licensed.
Specs compiled from the AlohaMini GitHub repository, its published bill of materials, and the project's own site as of this build. Manufacturer legal-entity claims and pricing outside the project's own BOM were not independently verifiable — confirm before purchase.